Engineer systems
that move.

Plan, design, develop, commission, validate, deploy, and maintain physical robots in one traceable workspace—from first mission brief to field-ready system.
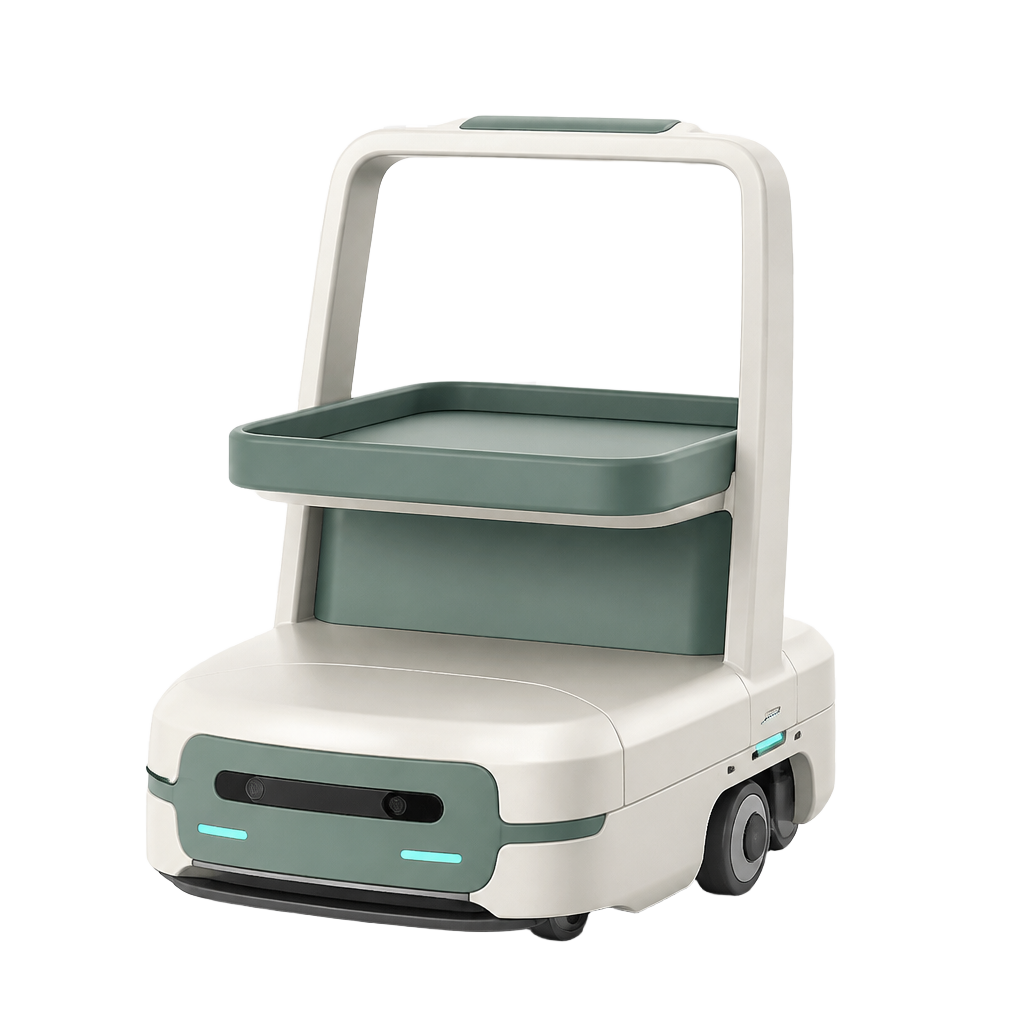
Friendly autonomous mobile service robot with a compact wheeled base and cargo shelf
MADE TO WORK ALONGSIDE PEOPLE SENSE · NAVIGATE · ASSIST
AI agent ready
Describe the mission. Get an engineering brief—free, no account needed.
Robotics Controls AI / ML Automation Field Operations
07
Robotics specialist agents
06
Lifecycle stages connected
01
Traceable engineering thread
HW+SW
Physical and digital systems
01 The toolkit

From first brief to a robot that works.

One connected engineering thread carries each decision from the workbench into the field.

01 / 04

Define the mission

Turn outcomes, constraints, and acceptance into a plan every discipline can build from.

Next: meet your specialists
Photorealistic rendered collaborative industrial robot arm with a precision gripper
02 Specialist agents

The right expertise, in the robot’s context.

Choose a discipline. See how its specialist moves the work forward.

01 / 06

Robotics engineer

Connect the mechanical, electrical, and software decisions that shape the complete machine.

Explore the engineering workspace
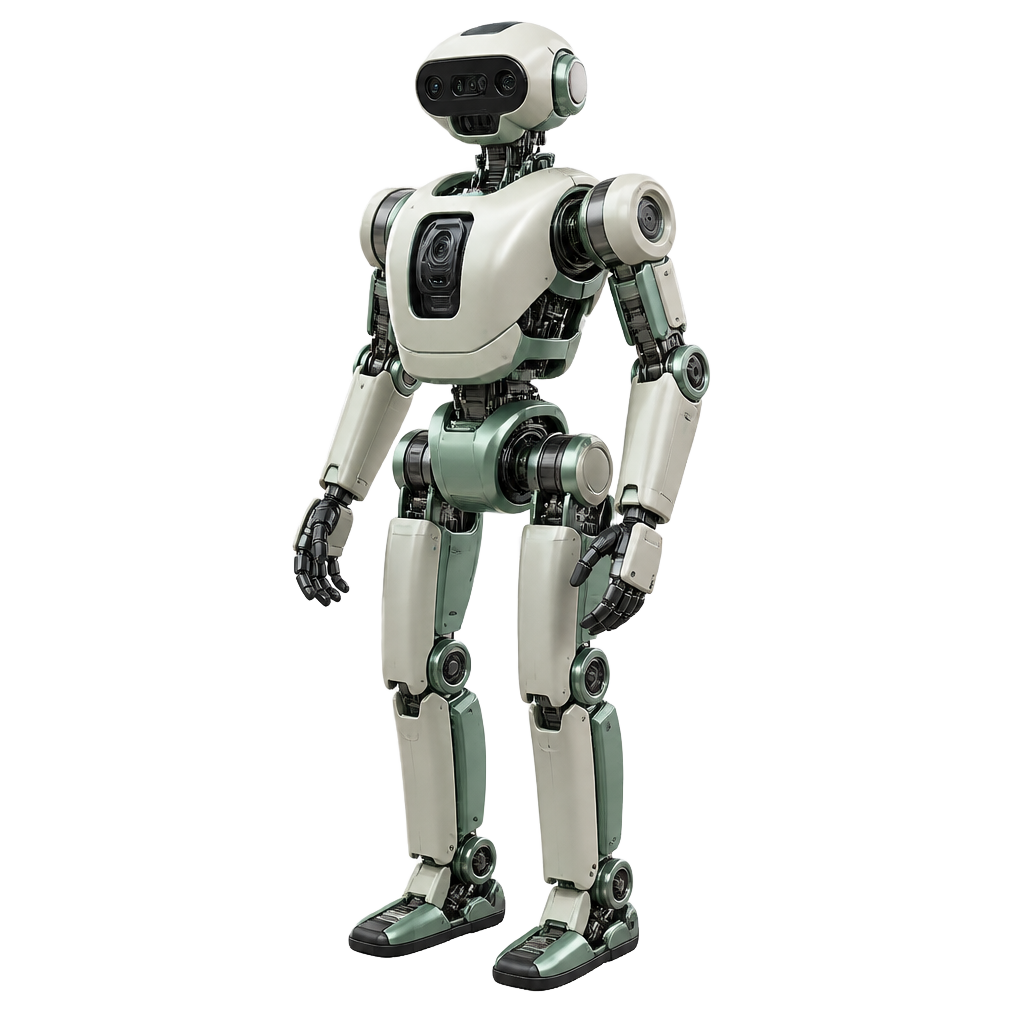
Photorealistic rendered humanoid robotics assistant with precision joints and sensor head
03 Who we serve

Different disciplines. One machine to move forward.

Every role gets a clearer view of the same system and its next decision.

01 / 05

Robotics teams

Link mechanical, electrical, software, and system-level work to the robot being built.

See who the workspace is for
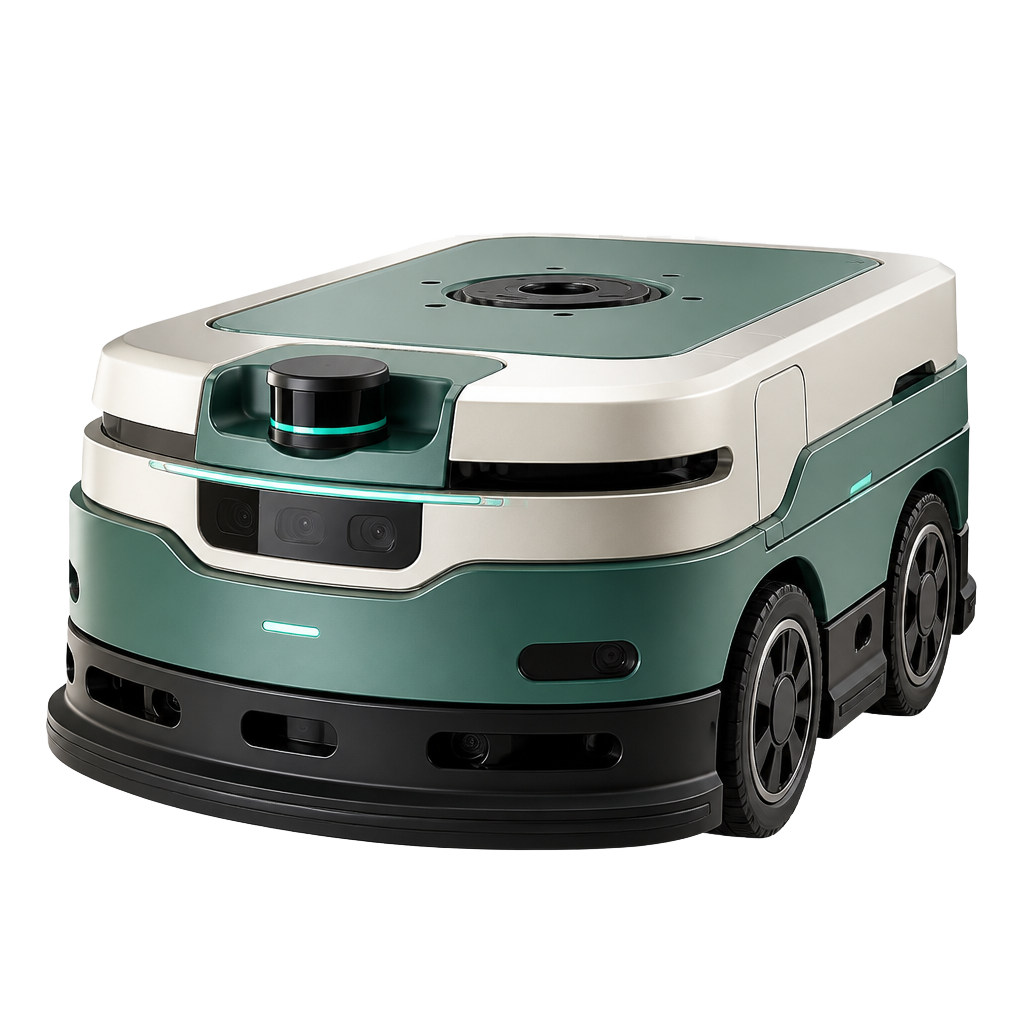
Photorealistic rendered autonomous mobile robot with lidar and depth cameras
04 How it works

Follow the idea all the way to the field.

Move through five connected moments in a robot’s lifecycle.

01 / 05

Define the mission

Set the operating environment, constraints, risks, and the evidence that will prove success.

Start with a system brief
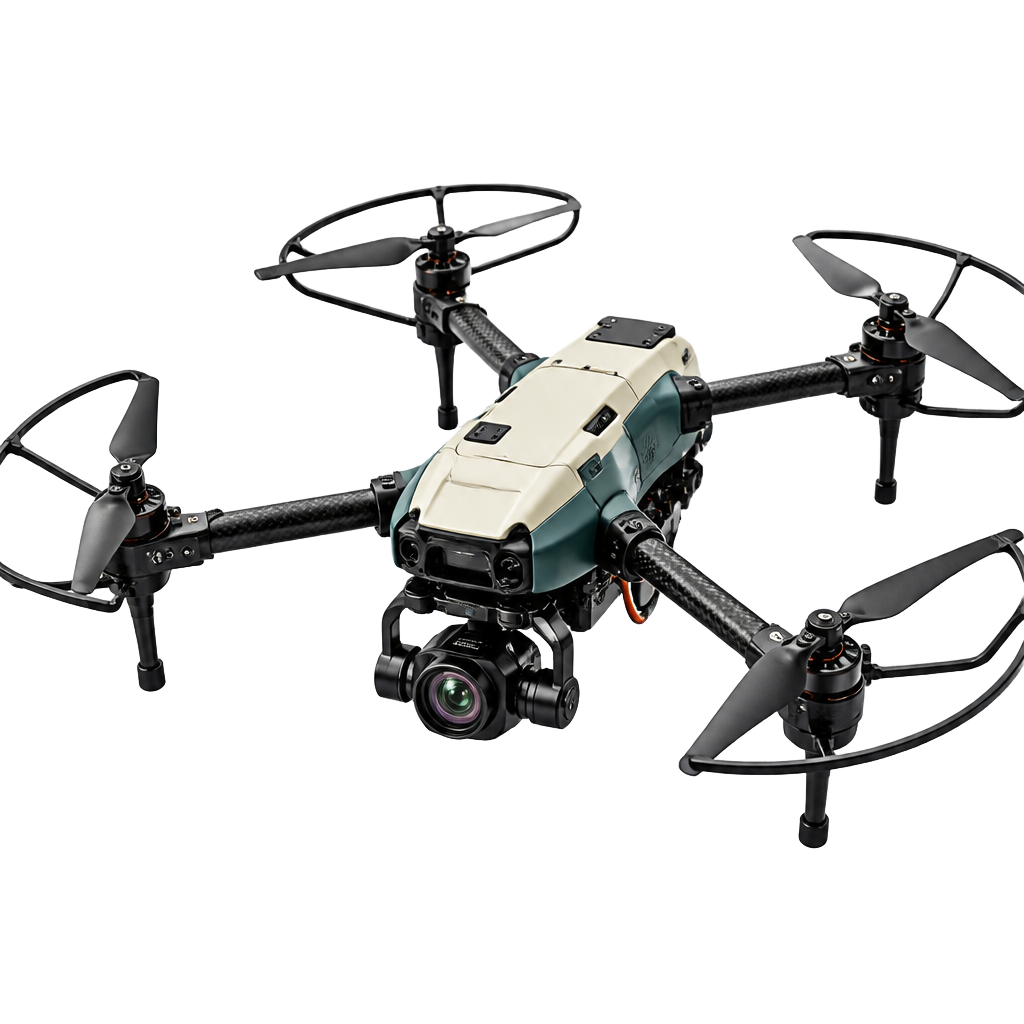
Photorealistic rendered industrial inspection drone with camera gimbal
One connected workspace for the robot lifecycle
Mission Requirements System Architecture Behavior Trees State Machines World Models Spatial Awareness Motion Planning Motion Controls Perception & SLAM Fault Tolerance PLC & HMI Integration Vision Inspection Specialist Agents SIL / HIL Testing FAT / SAT Fleet Orchestration Field Maintenance Mission Requirements System Architecture Behavior Trees State Machines World Models Spatial Awareness Motion Planning Motion Controls Perception & SLAM Fault Tolerance PLC & HMI Integration Vision Inspection Specialist Agents SIL / HIL Testing FAT / SAT Fleet Orchestration Field Maintenance
Why we're different

When the robot changes, the context should travel with it.

AI-Native Robotics OS connects engineering intent to interfaces, implementation, evidence, commissioning issues, and field updates.

Engineering context stays attached

Requirements, design decisions, work items, tests, issues, and evidence remain connected to the system they change.

Specialists speak their discipline

Hardware, controls, autonomy, AI/ML, automation, service, and research agents respond with the right assumptions and verification lens.

Readiness is backed by evidence

Move from prototype to deployment with explicit owners, blockers, acceptance gates, fault handling, commissioning actions, and handover records.

Give every robot program a shared engineering thread.

Start with one system brief. Bring together the people, decisions, evidence, and work needed to get the robot into the world.